From Theory to Practice: Embodied Learning in Action
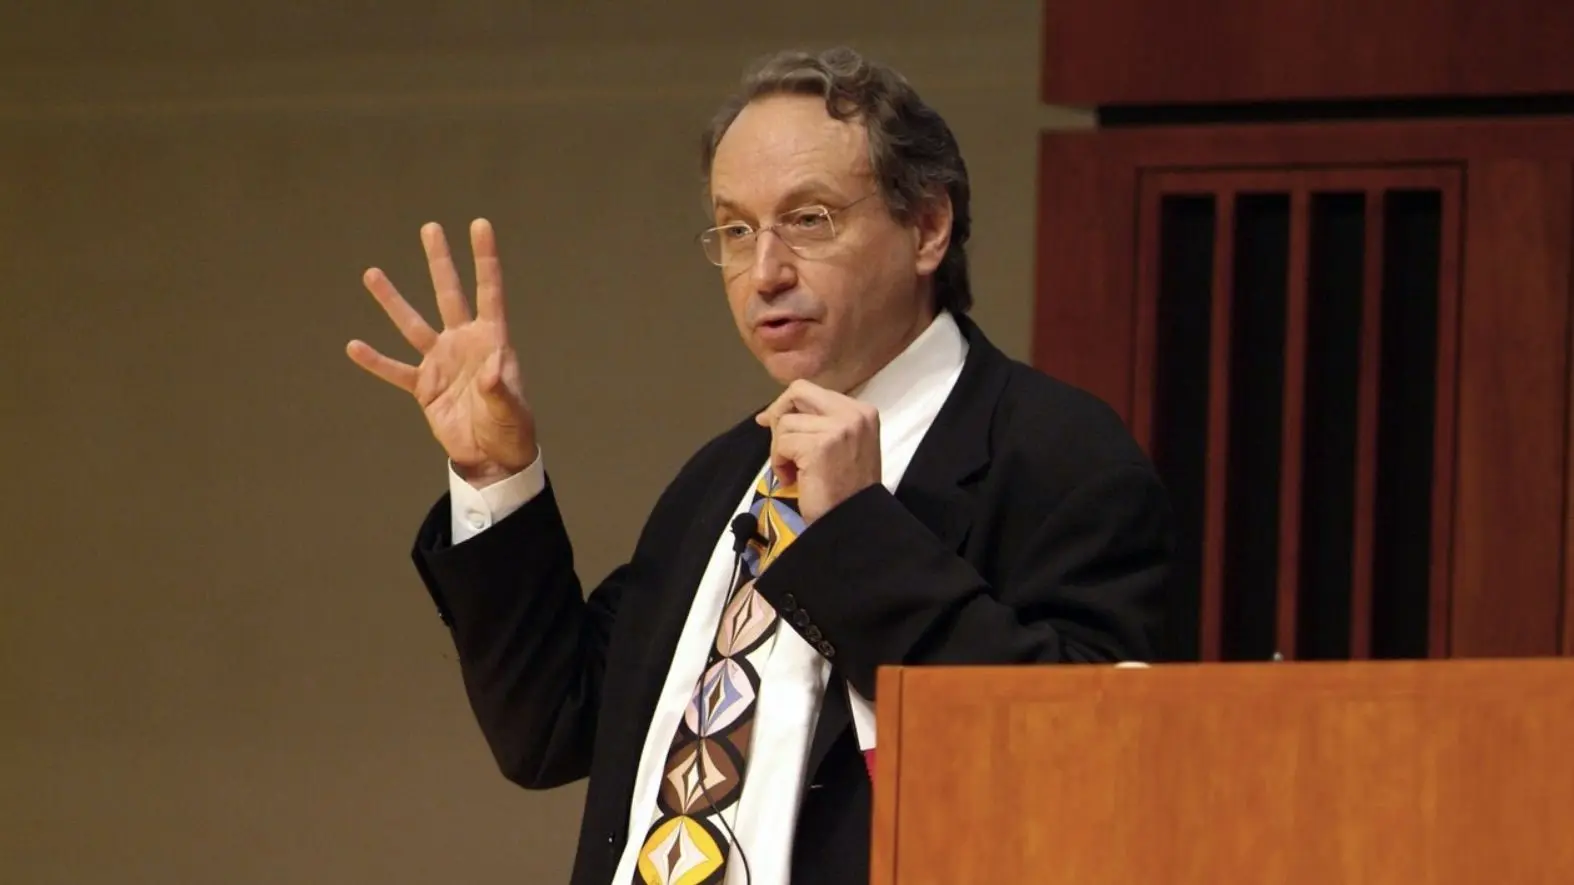
Rodney Brooks, co‑founder of i Robot, delivered a provocative statement on 12 October 2026 that has reverberated through the robotics community. He declared that „the world is its own best model,” challenging prevailing assumptions about how robots learn and interact with their environments. The remark, made during a keynote at the International Robotics Conference in Tokyo, has sparked renewed interest in embodied intelligence and set the stage for a surge in physical AI development.
Latest news
 Corsair Vengeance DDR5-6000 Kit Offers Ideal Speed for AMD Builds
 Hide.me VPN releases major Android update
 Hackers launch massive PHP2Shell attack wave
 Googlebooks are not yet ready for prime time
Brooks’ claim builds on decades of research into sensorimotor learning. He argues that instead of relying on pre‑programmed rules or large datasets, robots should learn directly from their own physical interactions with the world. By treating the environment as a living laboratory, machines can develop adaptive behaviors that mirror biological organisms. This perspective counters the dominant data‑driven AI paradigm, which often neglects the nuances of real‑world physics.
Can Physical AI Replace Conventional Models?
In his speech, Brooks highlighted several demonstrative projects that illustrate embodied learning. One example involved a mobile robot that learned to navigate uneven terrain by continuously adjusting its gait based on tactile feedback. The robot’s control system evolved over weeks, achieving a 30% improvement in stability without human intervention. Another case study showcased a robotic arm that mastered delicate assembly tasks by trial and error, refining its grip strength through iterative testing. These experiments underscore the potential of physical AI to solve complex, unstructured problems that traditional algorithms struggle with.
Brooks also emphasized the importance of hardware-software co‑design. He noted that future robots will need to integrate lightweight, energy‑efficient sensors with flexible control architectures. By aligning mechanical design with learning algorithms, engineers can create systems that adapt more rapidly to new tasks. The speaker cited a partnership between a robotics firm and a materials science laboratory that produced a compliant chassis capable of absorbing shocks while providing rich proprioceptive data.
Frequently Asked Questions
Is the shift toward embodied intelligence a revolution or an incremental refinement? Brooks suggests it is a revolution. He argues that conventional models, which rely heavily on curated datasets, are ill‑suited for unpredictable real‑world scenarios. Physical AI, by contrast, learns from the very act of doing, allowing robots to develop robust, context‑aware behaviors. Critics caution that embodied learning is computationally intensive and may require new hardware standards. However, early adopters report significant gains in autonomy, with robots completing tasks in dynamic environments that previously demanded human oversight.
The implications extend beyond robotics. Industries such as manufacturing, healthcare, and logistics could benefit from systems that self‑optimize through interaction. For instance, surgical robots that adjust force feedback based on patient response could improve precision and safety. In warehouses, autonomous forklifts that learn to navigate cluttered aisles could reduce downtime and increase throughput. These applications point to a future where physical AI becomes integral to everyday technology.
Comments
Leave a comment